
Three ways to move a finger, and a fourth

When people look at a robotic or prosthetic hand, they usually ask how many motors it has and where they are. Those are good questions, but they hide the one that decides how a hand behaves: what carries the motion from the motor to the joint. For us, the question of where the motors go […]
Twenty-seven degrees of freedom, and how many a hand actually uses
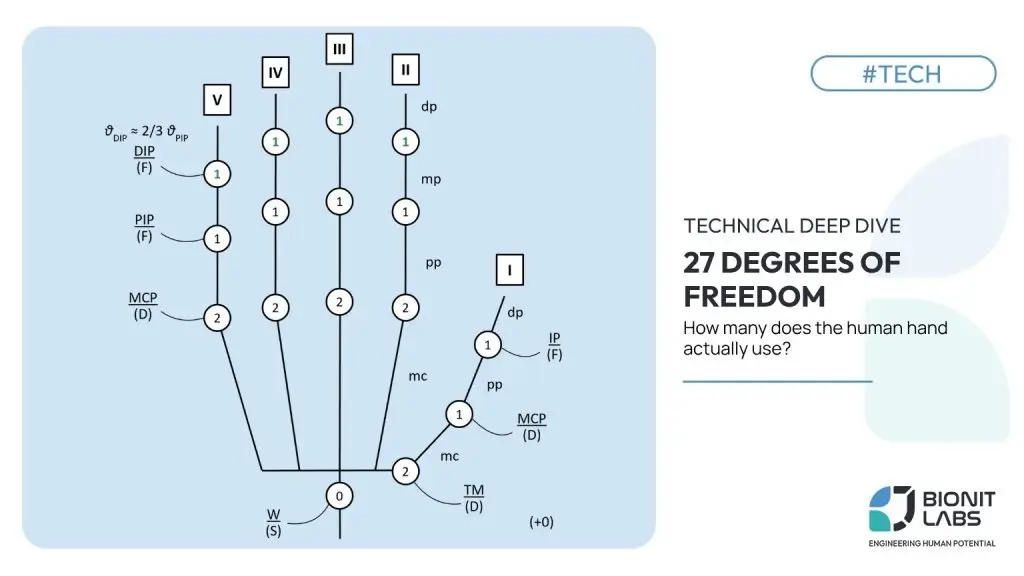
Adam’s Hand started because I was looking for a challenge. For a mechanical engineer, few problems are as interesting as the human hand. I still think of it as the most mechanically complex structure in the body: fast enough to catch a falling glass, strong enough to carry a suitcase, robust enough to take knocks […]
One motor, four fingers: the mechanism behind Adam’s Hand

People often ask me why Adam’s Hand drives its four long fingers with a single motor, when most multi-articulating prosthetic hands put a motor in every finger. The short answer is that a person wearing a prosthesis cannot steer four fingers one by one. The longer answer involves a gear mechanism that most of us […]
Evolving Our Identity: Engineering Human Potential

BionIT Labs unveils its new identity and expands from prosthetics into robotics, guided by a shared mission: Engineering Human Potential.
Four years of BionIT Labs: what we have learned

On the occasion of the fourth birthday of BionIT Labs, it is a great pleasure for me to share what our team has learned on their skin in these few years, hoping that our story will help those who fight every day to carry on their vision. A company can be considered a “living being” […]